Catalyst
The whole-robot library for FRC. Mechanisms, swerve, a state machine for the entire robot, physics, autonomy and telemetry, configured through builders instead of rewritten every season.
- Stable
- 1.12.0 · roboRIO, WPILib 2026
- Next
- 2.0.0-rc.1 · Systemcore, WPILib 2027
- Built on
- CTRE Phoenix 6, Java
Why
A mechanism is a description
Every FRC season a team rewrites the same elevator, arm and shooter: motor setup, feedforward, soft limits, simulation, logging. Catalyst turns that into a description of the mechanism. You say what it is; the library does the rest the same way every time.
// Catalyst 2.0: a two-motor elevator with named positions
LinearMechanism elevator = new LinearMechanism(
    LinearMechanism.Config.builder()
        .name("Elevator").motor(13).follower(14, true)
        .motorType(MotorType.KRAKEN_X60)
        .gearRatio(10.0).drumRadius(0.0254)
        .range(0.0, 1.2).mass(5.0)
        .pid(50, 0, 0.5).gravityGain(0.35)
        .motionMagic(2.0, 4.0, 20.0)
        .position("STOW", 0.0).position("HIGH", 1.1)
        .build());

new Trigger(operator::getYButton).onTrue(elevator.goTo("HIGH"));
That elevator comes with Motion Magic, gravity feedforward, a physics simulation, SysId, live tuning and telemetry under /Catalyst/Elevator/, without another line.
Versions
Two computers, one library
FIRST is moving from the roboRIO to Systemcore. Catalyst follows both: 1.x for the robots that compete now, 2.0 for the new controller and WPILib 2027.
| Line | Latest | Runs on | Install | Use it for |
|---|---|---|---|---|
| 1.x | 1.12.0Aug 7, 2026 | roboRIO · WPILib 2026 · Java 17 | JitPack, or the stable vendordep | Competition robots |
| 2.0 | 2.0.0-rc.1Oct 16, 2026 | Systemcore image 14 · WPILib 2027 alpha-7 · Java 25 · Phoenix 26.70 | JitPack, or the beta vendordep | The new controller |
| 2.0 alpha-6 | 2.0.0-rc.4-a6Oct 1, 2026 | Systemcore image 13 · WPILib 2027 alpha-6 | Source build only | The first Systemcore image |
2.0 moves to Commands v3 and Java 25, yet 974 of 986 public methods kept their names, so porting a robot is a short list of renames.
What's in it
The whole robot
10 mechanism builders
Elevators, arms, turrets, flywheels, claws and more, each self-simulating and self-tuning.
Whole-robot state machine
Superstructure runs every mechanism as one machine.
Swerve + vision
Drive-to-pose, pathfinding and Limelight MegaTag fusion.
Physics Core
Slip, collisions, live centre of mass, self-identified parameters.
Autonomy 2.1
Shared control that helps the driver instead of taking over.
Telemetry + tuning
Everything on NetworkTables, SysId everywhere, eleven browser tools.
The suite
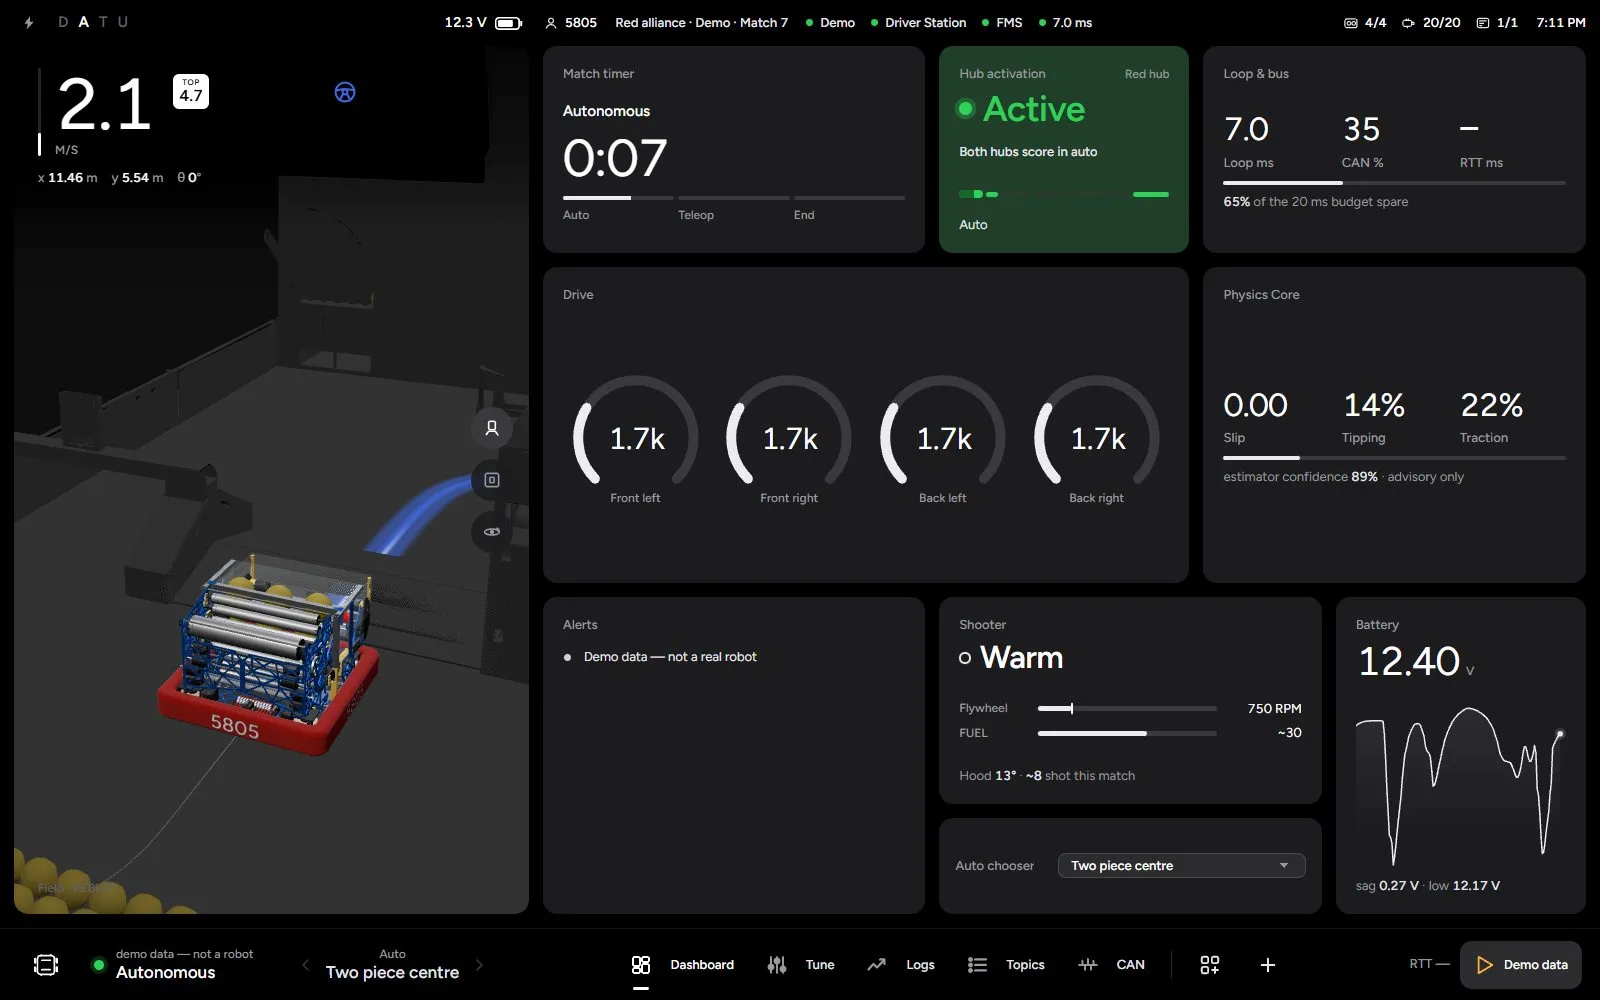
Apps around it
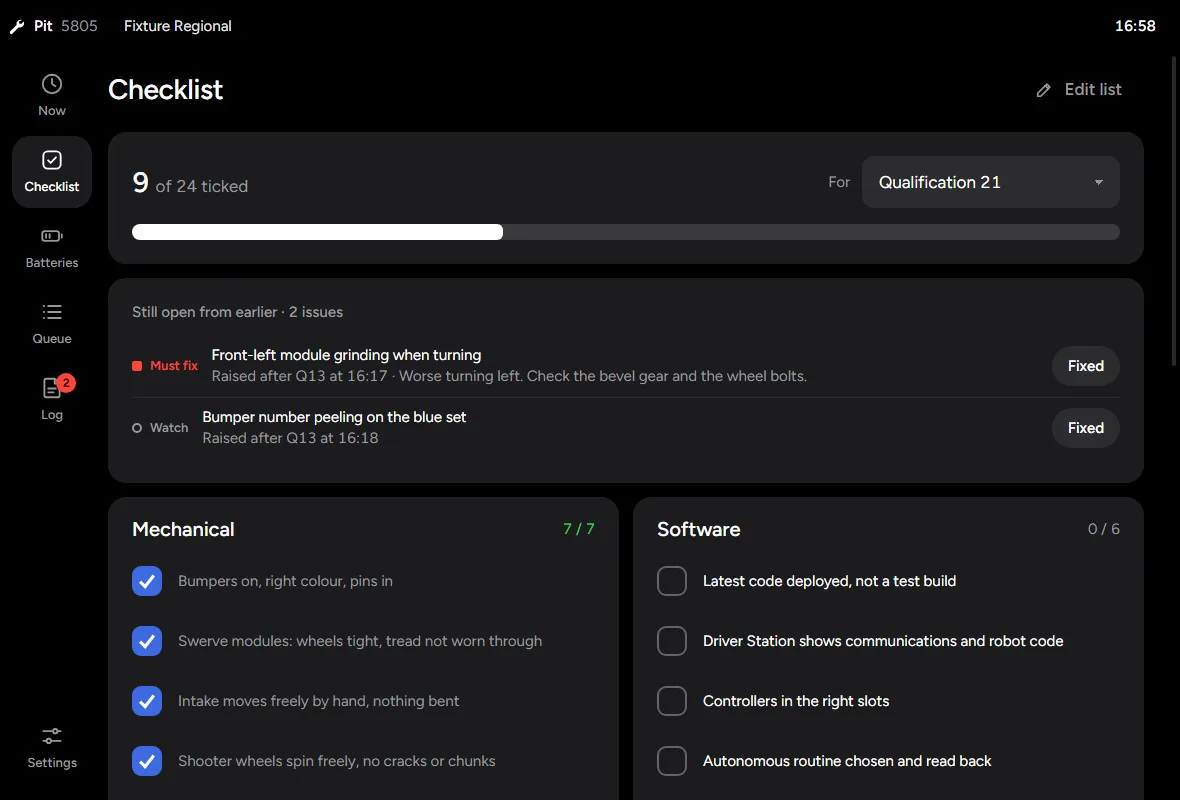
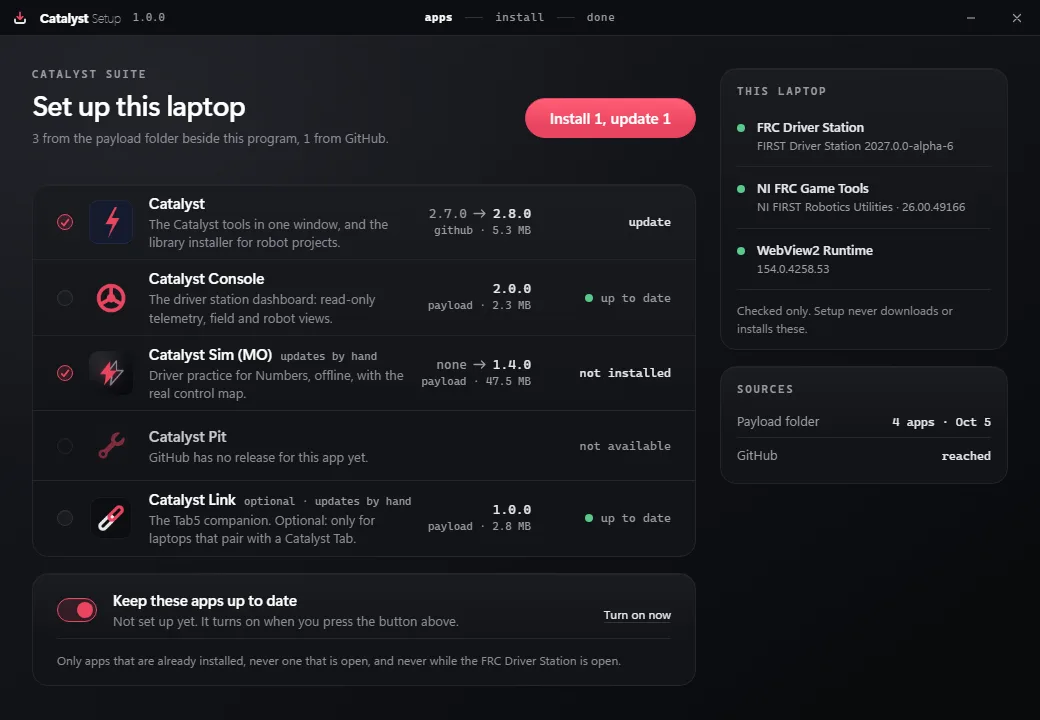
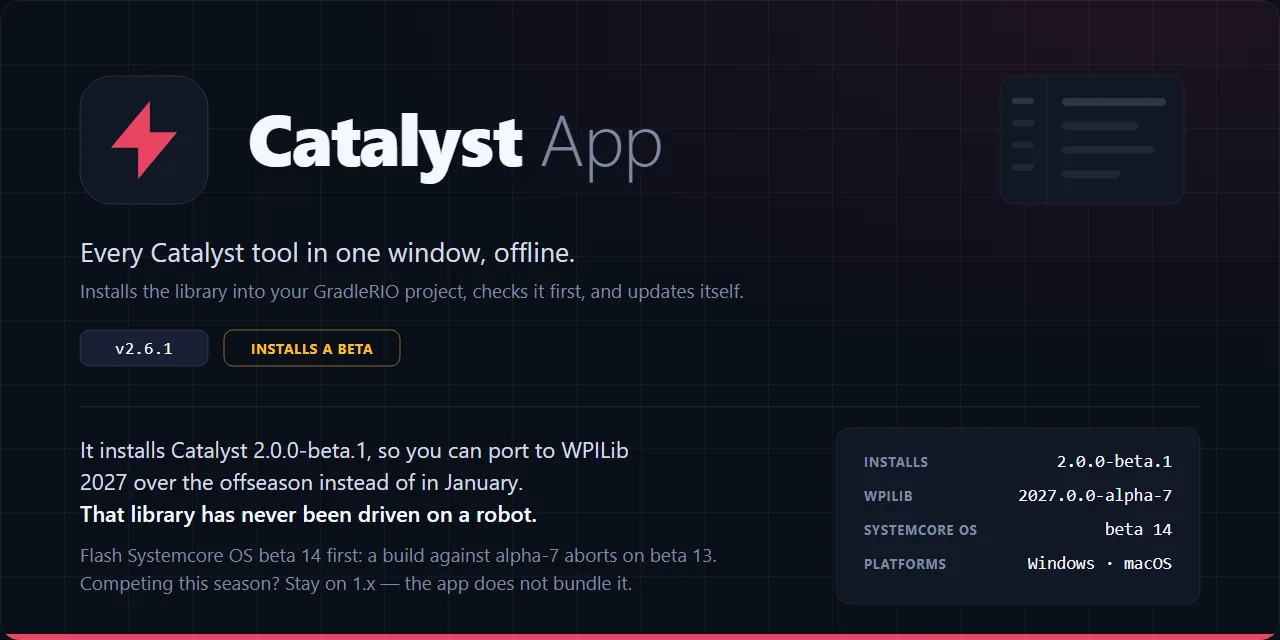
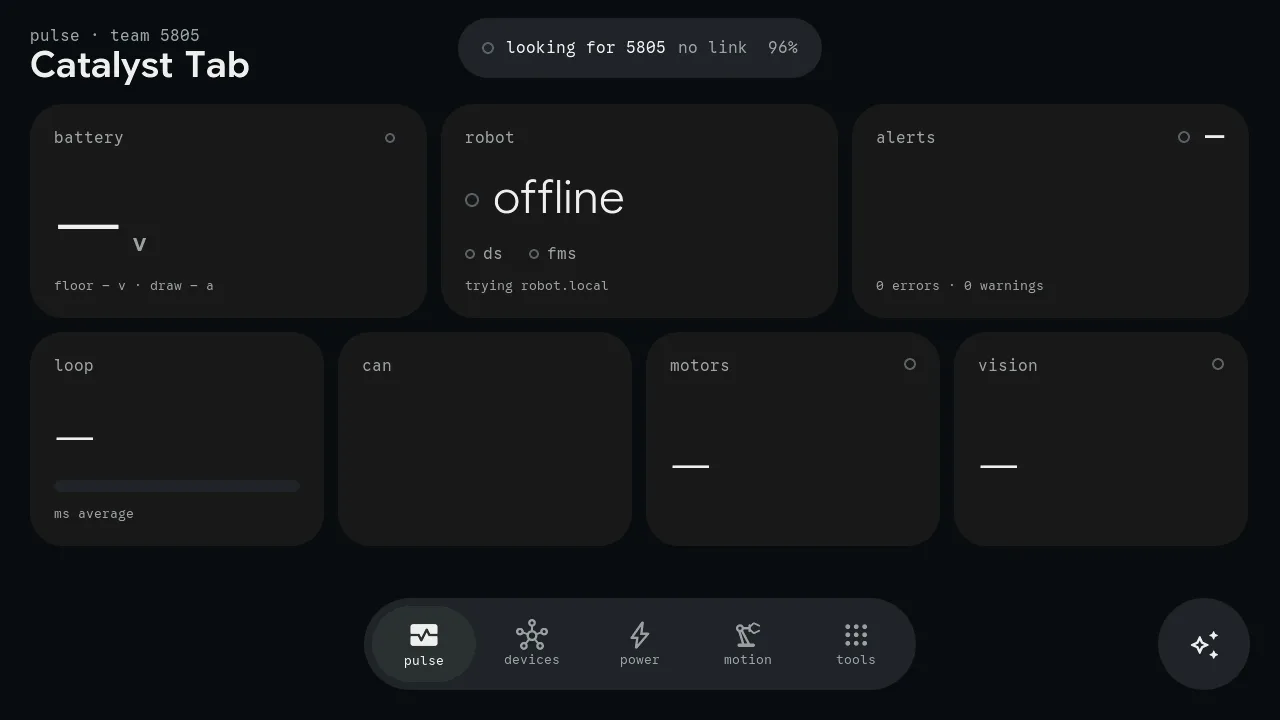
On a robot
Numbers
Every mechanism on Numbers is a Catalyst builder. New features drive on X1 first.